Skip to content

Figures

Every figure on this site is drawn by a Python module from facts extracted from the code, so it is rebuilt, not redrawn, when the code changes. CI runs hardfoc-docs figures --check and fails when a committed figure no longer matches the code. Each figure below lists the files it is drawn from.

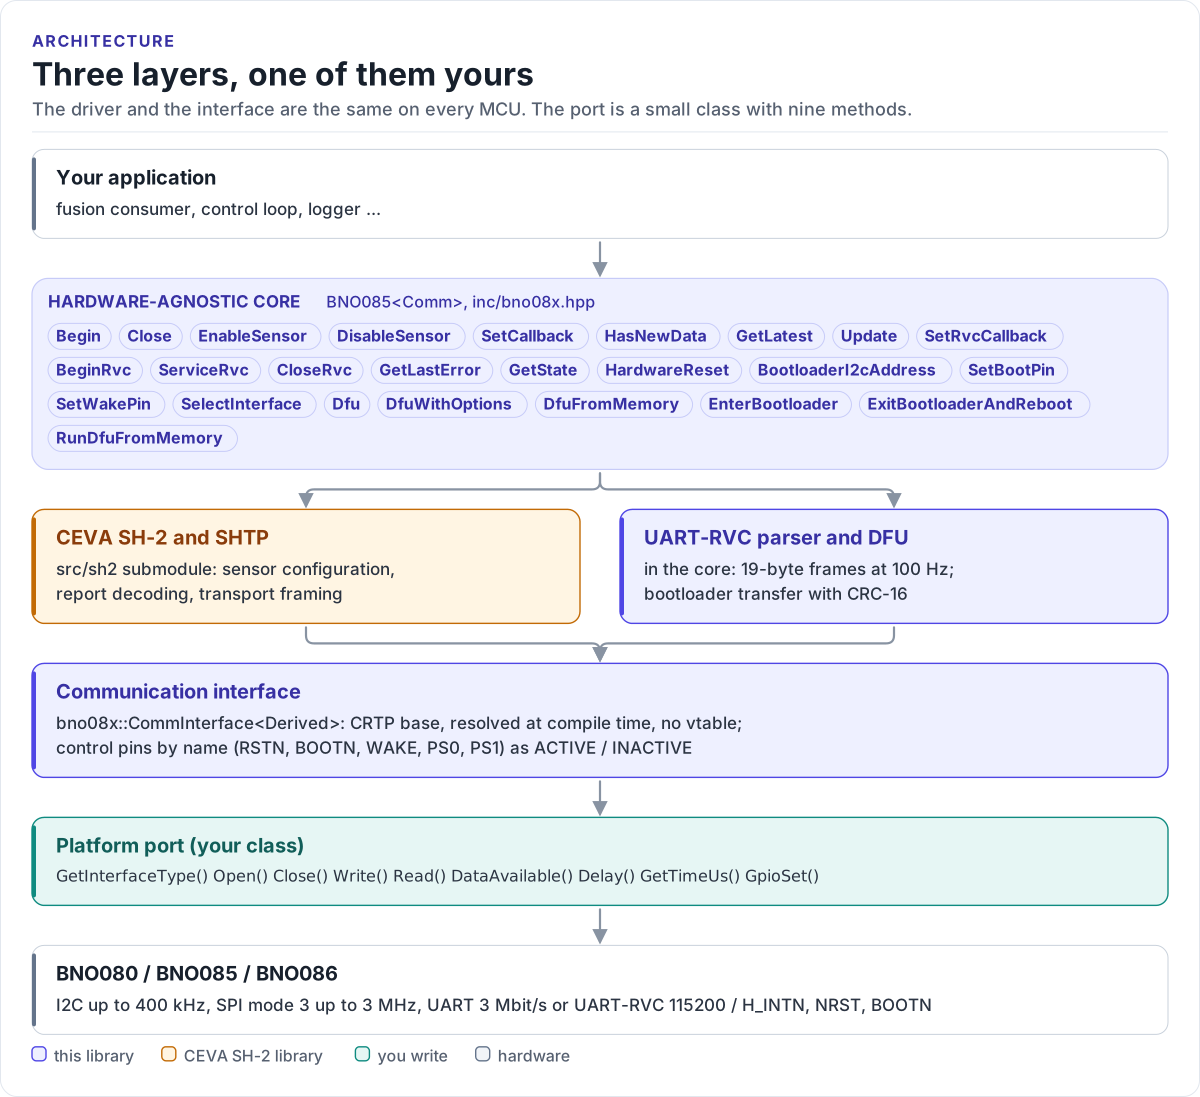
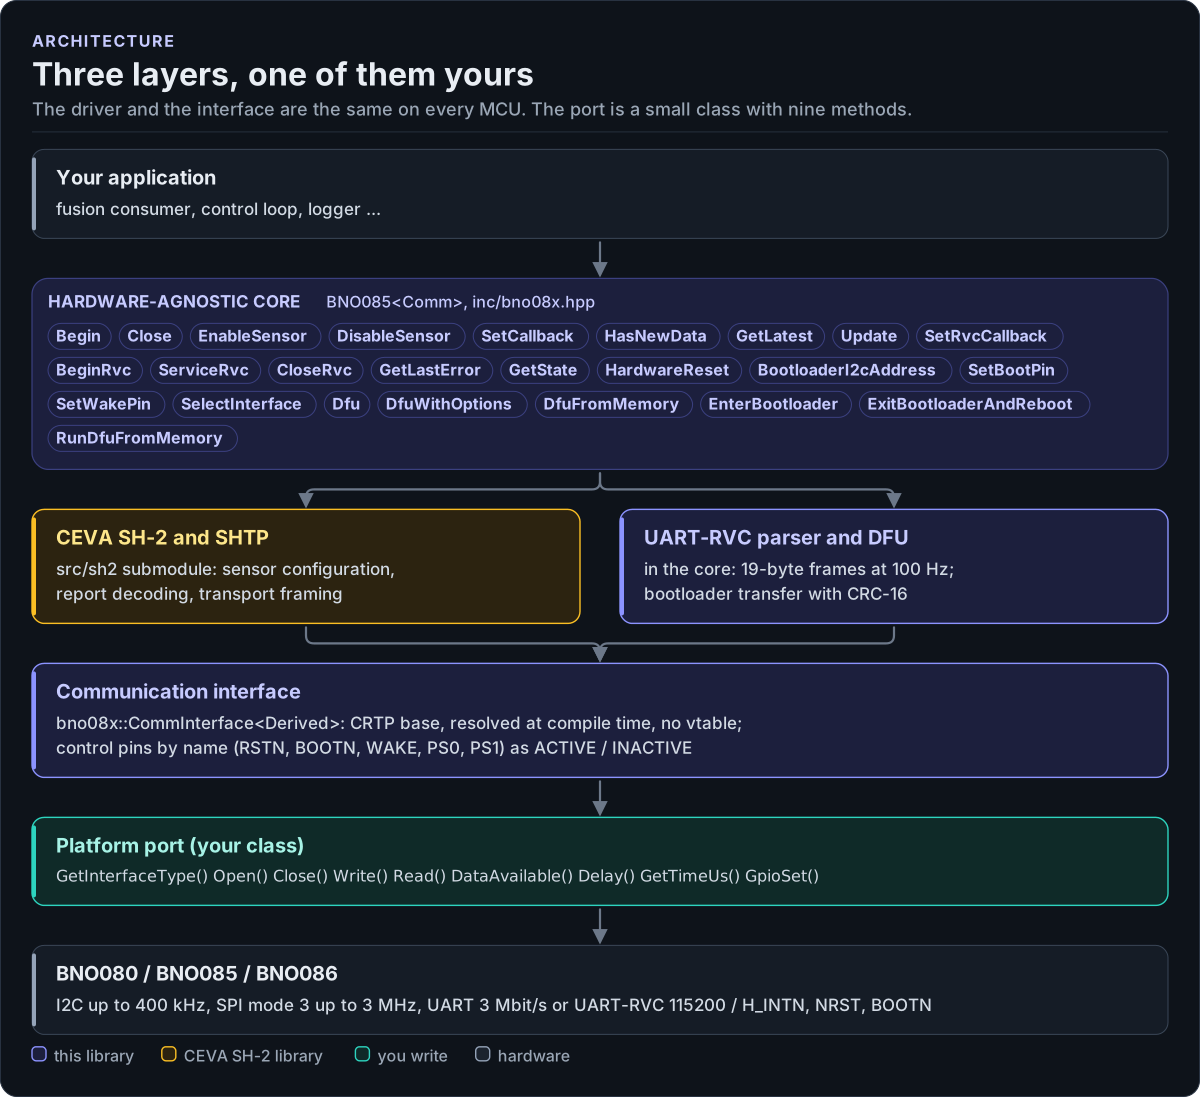
Three layers, one of them yours

Layer diagram: the application calls the hardware-agnostic BNO085 driver, which uses the CEVA SH-2 library or its own UART-RVC parser, then the CRTP communication interface, which calls the platform port you write, which drives the I2C, SPI or UART bus and the control pins of the BNO08x.Layer diagram: the application calls the hardware-agnostic BNO085 driver, which uses the CEVA SH-2 library or its own UART-RVC parser, then the CRTP communication interface, which calls the platform port you write, which drives the I2C, SPI or UART bus and the control pins of the BNO08x.
Three layers, one of them yours
Figure description and sources

From top to bottom. Your application talks to one BNO085 object, whose public calls are listed from inc/bno08x.hpp. In SH-2 mode the core hands every transfer to the CEVA SH-2 and SHTP library (the src/sh2 submodule); in UART-RVC mode it parses the 19-byte frames itself; firmware updates use the bootloader protocol in the core. Both paths end in the communication interface (bno08x::CommInterface in inc/bno08x_comm_interface.hpp), a CRTP base whose methods your platform port implements: move bytes, report data-ready, wait, keep time and drive the control pins. Below it is the sensor hub.

Drawn from: inc/bno08x.hpp BNO085 public members; inc/bno08x_comm_interface.hpp CommInterface; figure module docs/diagrams/figures/driver-layers.py.

Figure module: docs/diagrams/figures/driver-layers.py

Drawn from: